Description
5 + 1 DOF High-Torque Serial Bus Servo Robotic Arm Kit, Based On ESP32, 2-DOF Wrist Joint, Supports Flexible Expansion And Secondary Development, Wireless Control, Compatible With LeRobotRoArm-M3
5 + 1 DOF High-Torque Serial Bus Servo Robotic Arm
Supports flexible expansion and secondary development
* for reference only, please refer to the Package Content for the detailed part listProduct Introduction
RoArm-M3 seriesis a 5 + 1 DOF smart robotic arm designed for innovative applications. Adopts lightweight structure design with an effective payload of0.2kg@0.5m, it can be flexibly mounted on various mobile platforms. Adopts a 360° omnidirectional base combined with five flexible joints to create a workspace with 1-meter diameter.
The joint direct-drive design enhances repositioning precision and also improves structural reliability, with innovative dual-drive technology doubling the shoulder joint torque. Onboard ESP32 MCU main control module, supports multiple wireless control modes, and provides control interfaces and rich communication protocols for easily connecting to various devices.
Provides a user-friendly and cross-platform WEB application that integrates a simple and visualized coordinate control mode, making it easier to get started. Comes with rich graphic and video tutorials to help you learn and use it quickly. Compatible with ROS2 and various host computers, supports various wireless and wired communication modes. Comes with expansion plates, supports customizing the EoAT (End of Arm Tooling) to meet innovative application requirements.
At the same time, theRoArm-M3 seriesalso supports the popular AI robotic arm projectLeRobot, integrating its pretrained models, datasets with demonstrations, and simulation environments, providing strong support for research directions such as Deep Learning, Imitation Learning, and Reinforcement Learning. By utilizing the demos and algorithm libraries of LeRobot, developers can quickly deploy intelligent algorithms onto the RoArm-M3, further expanding the possibilities for innovative applications.
RoArm-M3 seriesachieves an excellent balance between lightweight, user-friendliness, expandability, and open innovation, it is a multi-functional robotic arm that integrates intelligent control, human-machine interaction, and customizable development. Ideal for applications that require a combination of flexibility, expandability, and user-friendliness.
Version Options
Provides options for RoArm-M3-S / RoArm-M3-Pro. The RoArm-M3-Pro is equipped with 5x all-metal ST3235 bus servos, offering a more rugged body and stable backlash that won't increase with use, enhancing product durability.
Parameter Comparison
* Not including the weight of the table edge fixing clamp (290±10g).
Compatible with the popular AI robotic arm project - LeRobot
The RoArm-M3 robotic arm series supports the open-source LeRobot framework on Hugging Face, providing core resources such as pretrained models, datasets with human collected demonstrations, and simulation environments. When combined with the N-VIDIAJetson Orin NXmotherboard or a PC with an N-VIDIA discrete GPU, users can experience the complete process of Imitation Learning and Reinforcement Learning projects.
Flexible joints × omnidirectional space
Adopts 360° rotation base and flexible joints to create an omnidirectional operating space with 1-meter diameter, allowing the Robotic Arm to move freely in all directions
2 DOF Wrist Joint + EoAT
for more flexible clamping
Equipped with 2 DOF wrist joint with pitch + horizontal rotation support, enables seamless coordination with the EoAT for multi-dimensional clamping and operation
Easy to control via
Cross-platform Web Application
No App installation required, access after entering the address. Allows users to connect and control RoArm-M3 via mobile phones, tablets and computers by clicking the buttons on the Web App. Supports secondary development of this open-source Web App to customize the user interface and add new functions.
Completely open source for
secondary development
Completely open source for the control codes and communication interface documents of RoArm-M3 series, supports multiple languages and devices for secondary development. Provides modularized demos and tutorials for zero-based users, easy to get started.
joint Direct-drive design
The response precision is up to 0.088°
The joint angle response can be obtained directly via the 12-bit high-precision magnetic encoder without any reduction groups, which is more accurate, and the actual position of the current target point can be calculated based on the joint angle response.
Innovative dual-drive technology
doubles the shoulder joint torque
We have developed a dual-drive control algorithm that allows the two servos at the shoulder joint to coordinate their output torque effectively, significantly enhancing the power and the overall load capacity of RoArm-M3 Series
Direct-drive clamp enables precise force control
The direct-drive clamp design allows precise control of the clamping force in the program, suitable for clamping delicate objects without applying excessive force
Dynamic external force
adaptive control
After enabling this function, you can limit the maximum torque for each joint. When the external force applied to the joint exceeds the torque threshold (configurable), the robotic arm will rotate in response to the external force, and will return to the specified position when the external force decreases below the torque threshold.
One-click automatic recording
Easy to create actions
RoArm-M3 can save JSON instructions for robot control as task files. The task files can be saved in the Flash of ESP32, which will not be lost in case of power loss. The robotic arm can perform complex and repetitive operations by calling these task files.
Accurately reach the target by entering the coordinates
Open source for inverse kinematics control algorithm in the three-dimensional Cartesian coordinate system. After entering the target position, the robot arm can accurately reach the target point by using the inverse kinematics function to calculate the rotation angle of each joint.
Curve Velocity Control for
Smoother movement
We use the curve velocity control algorithm to make the robotic arm move smoother and more naturally, without oscillations during start and stop
ESP-NOW wireless control
Low-delay remote collaboration
ESP-NOW is a low-delay ad hoc wireless communication protocol, without the need of Network infrastructures. You can use one robotic arm to wirelessly control other robotic arms, and the control methods can be set as broadcast control, group control, and one-to-one control.
* Note: The broadcast control has no limitation for the number of controlled devices, while the group control allows up to 20 devices. Please refer to the WIKI for more details.
Supports Leading-following control mode based on ESP-NOW
In the Leading-following control mode, the Leader robotic arm will send its joint angle information to other robotic arms via ESP-NOW communication. The other robotic arms which are in ESP-NOW Follower mode will imitate the same actions as the Leader in real time.
multiple control interfaces,
multiple devices and languages Support
RoArm-M3 series can be controlled not only by the WEB application, but also supports using other controllers to send JSON commands via HTTP protocol network request, serial communication, or USB communication for controlling and obtaining response.
Multiple installation methods for Integrating into Your Application
Provides multiple installation schemes and related secondary development resources, suitable for different usage scenarios and can be flexibly integrated into your projects and applications
Easy To install different peripherals
The main structure of the upper arm adopts two 1020 European standard aluminum rails, supports installing additional peripherals via the boat nuts to meet different needs. Comes with boat nuts and corresponding M4 screws for easy installation.
Supports installing a camera to extend visual applications
Comes with a camera holder and open source for the related drawings. You can directly install a camera with the corresponding size or other cameras with an adapter
* for reference only, only the LED light is included.
Onboard ESP32 Main control board
Adopts ESP32 powerful main control MCU, supports Multiple wireless communication protocols, with a large amount of open source resources to help secondary development of innovative applications
Compatible with ROS2, Provides model establishment File and supports multi-device cooperation
Provides communication nodes of ROS2, URDF model description file and zero-based tutorial of ROS2
rich tutorial resources for
secondary development
We provide complete unit tutorials and cases, including various functions and common application scenarios, to help users get started quickly for secondary development
General Driver Board for Robots
Onboard rich interfaces and resources for innovative development and functional expansion
- ESP32-WROOM-32 controller module
Can be developed using Arduino IDE - IPEX 1 WIFI connector
For connecting WIFI antenna to increase the wireless communication distance - LIDAR interface
Integrated LIDAR adapter function - I2C peripheral expansion interface
For connecting with OLED screen or other I2C sensors - Reset Button
Press and release to reboot the ESP32 - Download button
Press when powering on to enter download mode - DC-DC 5V voltage regulator circuit
Provides power supply for host computers such as Raspberry Pi or Jetson nano - Type-C port (LADAR)
LIDAR data transmission - Type-C port (USB)
ESP32 communication interface, for uploading programs to ESP32 - XH2.54 power port
Support DC 7~13V input, can directly power the serial bus servos and motors - INA219
voltage/current monitoring chip - Power ON/OFF
External power supply ON/OFF - ST series serial bus servo interface
For connecting with ST3215 / ST3235 serial bus servo - Motor interface PH2.0 6P
Group B interface for motor with encoder
- Motor interface PH2.0 6P
Group A interface for motor with encoder - Motor interface PH2.0 2P
Group A interface for motor without encoder - Motor interface PH2.0 2P
Group B interface for motor without encoder - AK09918C
3-axis electronic compass - QMI8658C
6-axis motion sensor - TB6612FNG
Motor Control Chip - Serial bus servo control circuit
for controlling multiple ST3215 serial bus servos and obtaining servos response - TF card slot
Can be used to store logs or WIFI configurations - 40PIN GPIO header
For connecting with Raspberry Pi or other host boards - 40PIN extended header
Easy to use the GPIO pins of Raspberry Pi or other host boards - CP-2102
UART to USB, for LIDAR data transmission - CP-2102
UART to USB, for ESP32 communication - Automatic download circuit
For Uploading programs to the ESP32 without pressing the EN and BOOT buttons
Diversified onboard resources
Supports function expansion
Integrated with INA219 battery voltage Monitoring and 9-axis IMU sensor, supports function expansion and innovation
Mouse drag-and-drop interaction
Provides Web applications and desktop software (open-source programs developed by Python), supports setting action instructions when the mouse is pressed and released to control the robotic arm flexibly
SpecificationsDOF5 + 1Work spaceHorizontal diameter: 1120mm (Max, 360° omnidirectional), Vertical: 798mm (Max)Operating voltage12V 5A power supply, supports 3S Lithium batteries (NOT included)Load capacity0.2kg@0.5mrepositioning precision~ 5mmServo rotation speed40rpm (no-load, no torque limit)Operating rangeBASE-360°, SHOULDER-180°, ELBOW-225°, HAND-135°/270°Drive typeTTL Serial bus servo, direct-drive jointServo numbers7Joint angle sensor12-bit 360° magnetic encoderServo torque30KG.CM @12V, 20KG·CM @ 12V (EoAT)Joint response informationservo status, joint angle, rotation speed, joint load, servo voltage, servo current, servo temperature and servo working modeMain controlESP32-WROOM-32Main control module featuresWiFi, BT, Dual Core, 240MHzWireless control mode2.4G-WiFi, ESP-NOWWired control modeUSB, UARTManual operation modeWEB control interfaceHost operation modeUART / USB / WEB commands in JSON data formatHost supportUSB connection devices such as Raspberry Pi, Jetson Orin Nano, and PC.EoAT functionclamp function by default, can be changed as an additional degree of freedomLED power≤1.5WOLED screen size0.91inchOther functions2-ch 12V power supply switch, 9-DOF IMURobotic arm weightRoArm-M3-S: 973.5±15g
RoArm-M3-Pro: 1020.8g±15g
(Not including the weight of the table edge fixing clamp)table edge fixing clamp weight290±10gSupported table edge thickness of the clamp72mmDemo3D Cartesian coordinate system control (inverse kinematics control); Dynamic external force adaptive control; Joint angle control; Operating information response; FLASH files system operation; Steps recording and replaying; ESP-NOW control; Leading-Following mode (Hand guiding control); LED control; 12V power supply ON/OFF control; WiFi function settings; Set startup tasks; Serial bus servo settings; response mode setting, etc. (Note: Please refer to the WIKI for more details)
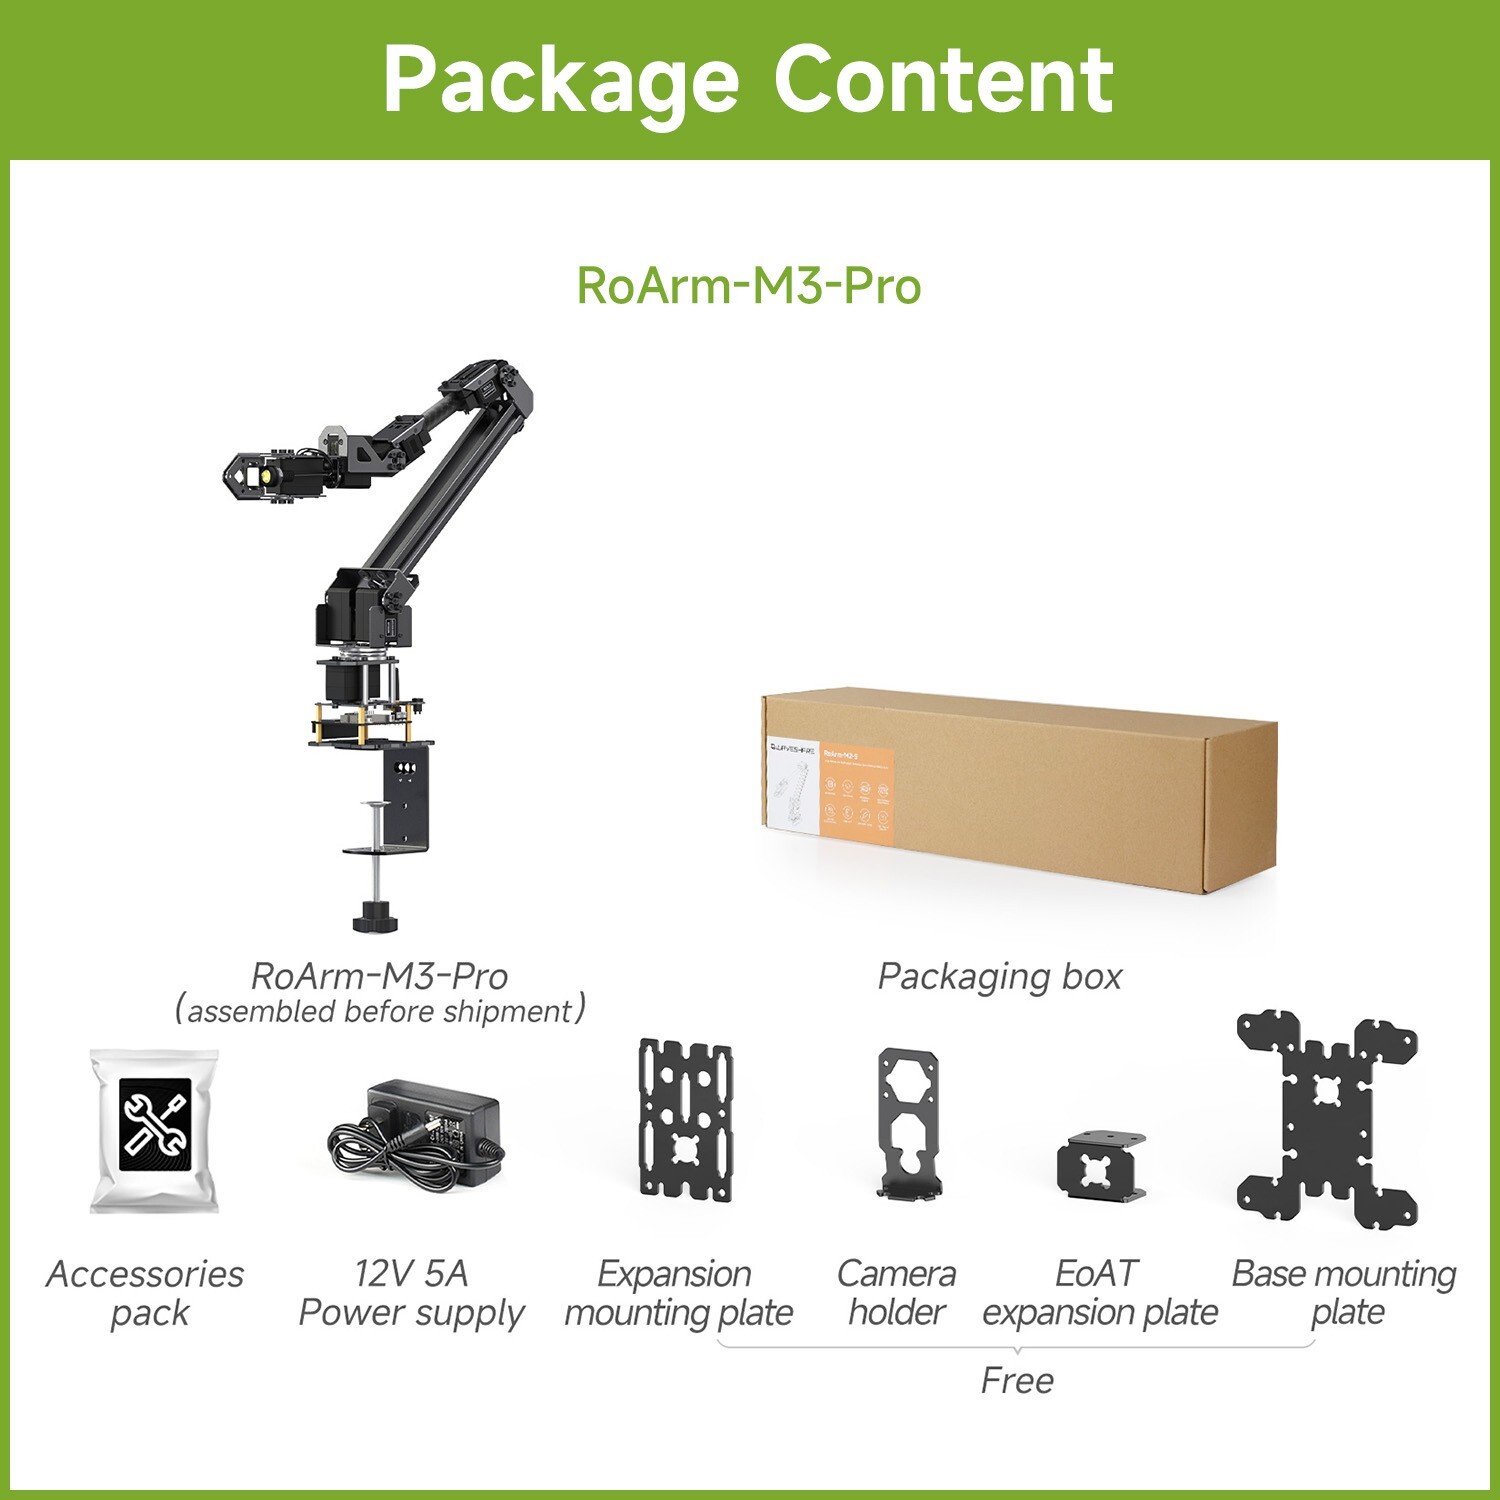
Product & Packaging showDimensionsResources & ServicesPackage Content
Weight:1.666 kg
RoArm-M3-SRoArm-M3-Pro